Obstacle Avoiding Bot ( Maze Solver )
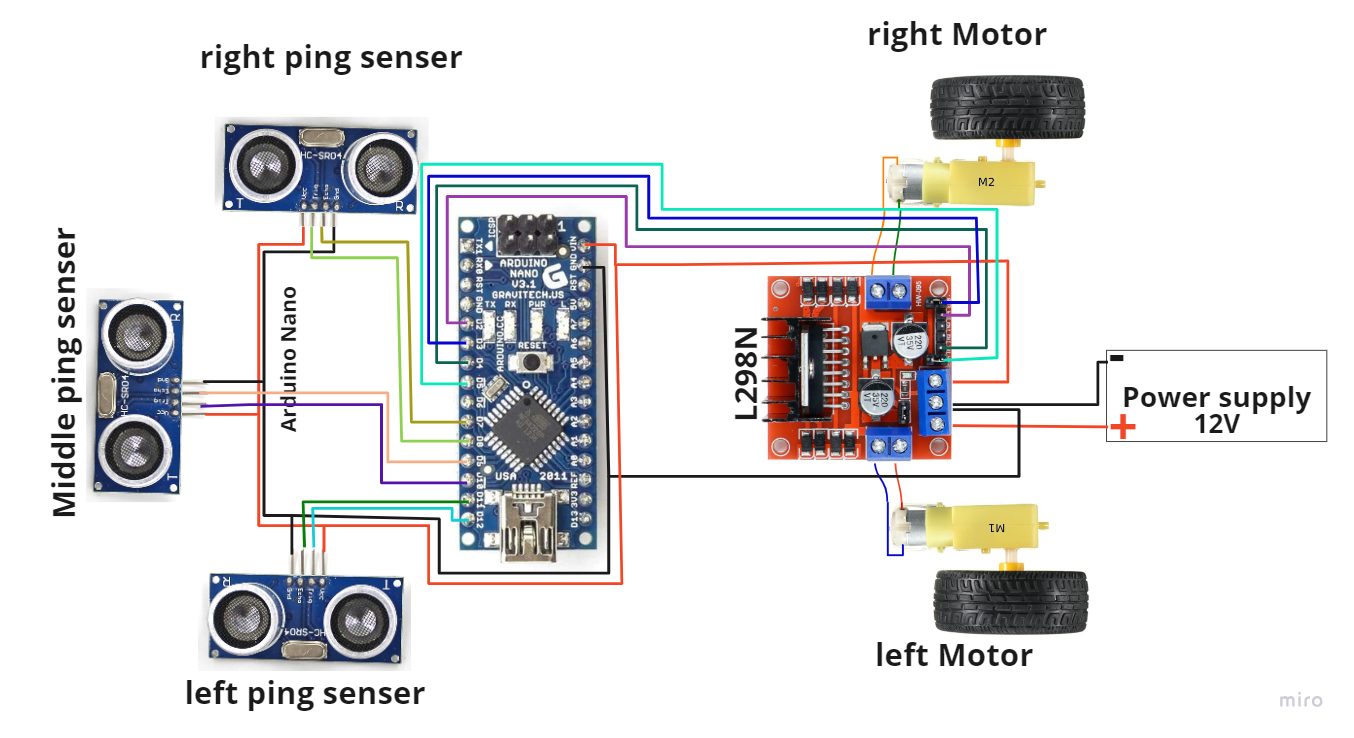
This is the Obstacle Avoiding / Maze Solver Bot Code & Circuit Diagrams Main Components Required 1 . Arduino UNO / UNO R3 - 01 2 . L298 Motor Driver - 01 3 . N20 300rpm Motor - 04 4 . Caster wheel - 04 5 . Ultrasonic Senser - 03 6 . Some Jumper Wires 7 . 12V Battery **---------------code starts here---------------** // Pin definitions for motors and ultrasonic sensors const int leftMotorPin = 2; const int rightMotorPin = 4; const int frontUltrasonicTrigPin = 11; const int frontUltrasonicEchoPin = 12; const int leftUltrasonicTrigPin = 9; const int leftUltrasonicEchoPin = 10; const int rightUltrasonicTrigPin = 7; const int rightUltrasonicEchoPin = 8; const int motorPinA = 3; const int motorPinB = 5; // Maximum distance to consider an obstacle (in centimeters) const int obstacleDistance = 15; void setup() { // Initialize motor pins as outputs pinMode(leftMotorPin, OUTPUT); pinMode(rightMotorPin, OUTPUT); pinMode(motorPinA,...